Control of Complex Systems

64 690,00 Ft
+ 2 049,00 Ft szállítási költség

Control of Complex Systems
Értékesítő:

64 690,00 Ft

Készleten
+ 2 049,00 Ft szállítási költség

14 napos visszaküldési szabályzat

Vásárlóvédelem

Fizetési módok:

  • Márka: Unbranded

Termékadatok

Termékadatok

Control of Complex Systems

1. Introduction. - 1. 1 Complex Systems and Control. - 1. 2 Complex Engineering Systems. - 1. 3 The Role of Feedback. - 1. 4 Dynamics and Control. - 1. 5 The Nature of Failures. - 1. 6 Research Challenges. - 1. 7 About the Book. - 2. Modeling Complex Physical Systems. - 2. 1 Introduction. - 2. 2 The Modelica Project. - 2. 3 Composition Diagrams. - 2. 4 Modelica Details. - 2. 5 Non-causal Modeling. - 2. 6 Advanced Modeling Features. - 2. 7 Standard Libraries. - 2. 8 Future Development. - 2. 9 Conclusions. - 3. Passivity-based Control of Non-linear Systems. - 3. 1 Introduction. - 3. 2 Passivity and Stability Analysis of Feedback Interconnections. - 3. 3 Feedback Passivity and Stabilization. - 3. 4 Euler-Lagrange Systems. - 3. 5 Disturbance Attenuation and R oo Control. - 4. An Introduction to Forwarding. - 4. 1 Introduction. - 4. 2 C1 Dissipative Systems. - 4. 3 C1 Dis sipative Systems via Reduction or Extension. - 4. 4 Exact Change of Coordinates. - 4. 5 Approximate Change of Coordinates. - 5. Iterative Identification and Control Design. - 5. 1 Introduction. - 5. 2 Youla Parametrization. - 5. 3 A Generic Two-degree of Freedom Controller. - 5. 4 Optimization of the Generic Scheme. - 5. 5 A New Closed-loop System Parametrization. - 5. 6 Asymptotic Variances for K-B-Parametrization. - 5. 7 Iterative Controller Refinement. - 5. 8 Robustness and Sensitivity. - 5. 9 Product Inequalities. - 6. Learning Control of Complex Systems. - 6. 1 Introduction. - 6. 2 Model Structures for Learning. - 6. 3 Control Structures for Learning. - 6. 4 Learning Paradigms. - 6. 5 A General Framework for On-line Learning. - 6. 6 Validation. - 6. 7 Conclusions. - 7. Software for Complex Controllers. - 7. 1 Introduction. - 7. 2 An Evolving Paradigm. - 7. 3 Emerging Software Concepts. - 7. 4 On to Standardization. - 7. 5 Sample Complex Software Controllers. - 7. 6 The Future of Software for Control. -8. Fault-tolerant Control Systems. - 8. 1 Introduction. - 8. 2 Basic Definitions. - 8. 3 Analysis of Fault Propagation. - 8. 4 Analysis of Structure. - 8. 5 Recoverability. - 8. 6 Autonomous Fault-tolerant Control. - 8. 7 An Example: Ship Propulsio. - 8. 8 Summary. - 9. Fault Detection and Isolation. - 9. 1 The Principle of Model-based Fault Diagnosis. - 9. 2 Signal-based FDI Approach. - 9. 3 Quantitative Model-based FDI Approach. - 9. 4 Qualitative Model-based FDI Approach. - 9. 5 Summary. - 10. Residual Generation for FDI in Non-linear Systems. - 10. 1 Introduction. - 10. 2 Algebraic Approach. - 10. 3 Geometric Approach. - 10. 4 Conclusion. - 11. Predictive Methods for FTC. - 11. 1 Introduction. - 11. 2 Predictive Control. - 11. 3 Embedding Fault Tolerance in Predictive Control. - 11. 4 Model Adaptation and Management. - 11. 5 Modifying Control Objectives. - 11. 6 Current Industrial Practice. - 11. 7 Conclusions. - 12. Three-tank Control Reconfiguration. - 12. 1 The Benchmark Problem. - 12. 2 Reconfigurability Analysis. - 12. 3 Reconfiguration Based on a Qualitative Model. - 12. 4 A Hybrid Approach to Reconfigurable Control. - 12. 5 A Multi-model-based Reconfigurable Control. - 12. 6 A Neural Observer-based Approach. - 12. 7 Conclusions. - 13. Ship Propulsion Control and Reconfiguration. - 13. 1 Introduction. - 13. 2 Ship Propulsion System. - 13. 3 Structural Analysis. - 13. 4 Fault Detection: A Fuzzy Observer Approach. - 13. 5 Fault Detection: Non-linear Approach - 1. - 13. 6 Fault Detection: Non-linear Approach - 2. - 13. 7 Reconfiguration Using Software Redundancy. - 13. 8 Reconfiguration Using Predictive Control. - 13. 9 Summary and Conclusions. - 14. Learning Control of Thermal Systems. - 14. 1 Introduction. - 14. 2 On Thermal System Learning Control. - 14. 3 Controlling Kiln Heat Processing. - 14. 4 Controlling Reheat Furnace Processes. - 14. 5 Hierarchical Control for Quality Ceramic Tiles. - 14. 6 Learning Control ofFBC Combustion. - 14. 7 Conclusions and Future Research. - 15. Vibration Control of High-rise Buildings. - 15. 1 Introduction. - 15. 2 Energy and Information. - 15. 3 Analytical Mechanics and HRB Modelling. - 15. 4 Disturbance Decoupling. - 15. 5 Passivity Based Control. - 15. 6 Engineering Constraints and Feedback. - 15. 7 Feedback Control and Testing. - 15. 8 Conclusions and Future Research. - 16. Control of Helicopters. - 16. 1 Introduction. - 16. 2 Project History. - 16. 3 The COSY Program. - 16. 4 Hardware System. - 16. 5 Software. - 16. 6 Design of the Autopilot. - 16. 7 Future Development. - 16. 8 Conclusions. - 17. Satellite Attitude Control. - 17. 1 Introduction to the Attitude Control Problem. - 17. 2 Fault-tolerant Control of the 0RSTED Satellite. - 17. 3 Stabilization of the Angular Velocity of a Rigid Body. - 17. 4 Optimal Slew Maneuvers via Geometric Control Theory. - 17. 5 Attitude Control using Magnetorquers as Sole Actuators. - 17. 6 Predictive Attitude Control of Small Satellites. - 17. 7 Attitude Determination without Sensor Redundancy. - 17. 8 Summary. - Appendix A. List of Contributors. - Appendix B. List of Abbreviations. - References. Language: English
  • Márka: Unbranded
  • Kategória: Oktatás
  • Művész: Karl J. Aström
  • Lapok száma: 482
  • Nyelv: English
  • Formátum: Paperback
  • Kiadás dátuma: 2012/09/27
  • Kiadó / Címke: Springer
  • Fruugo azonosító: 337872348-741531648
  • ISBN: 9781447110743
Ígéret

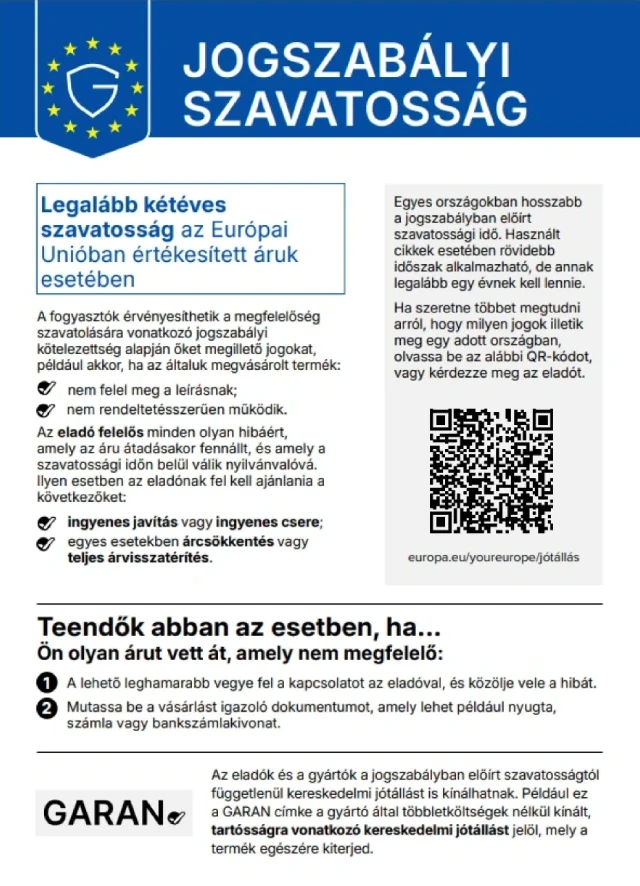
Eladói garancia

2 év jogi garancia benne foglaltatik

Az EU-s fogyasztói jogai közé tartozik egy legalább 2 éves ingyenes jogi garancia

Megfelelőségi jogi garancia letöltése
Szállítás

Szállítás

Kiküldés 5 napon belül

  • STANDARD: 2 049,00 Ft - közötti szállítás K 13 október 2026–P 16 október 2026

Szállítás innen: Egyesült Királyság.

Visszaküldés

Visszaküldés és lemondás

Visszaküldés

Minden tőlünk telhetőt megteszünk annak biztosítására, hogy rendelését hiánytalanul és előírásainknak megfelelően szállítás ki önnek. Viszont ha egy hiányos rendelést kap, vagy eltér a megrendelttől, vagy bármilyen más okból nem elégedett a rendeléssel, akkor visszaküldheti a rendelést vagy a rendelésben lévő bármely terméket, és visszatérítik a termék árának teljes összegét.

Teljes visszaküldési irányelvek megtekintése.

Lemondások

Jogod van elállni a vásárlástól a rendelés kézhezvételétől számított 14 napon belül indoklás nélkül. A jogod egyszerű gyakorlásához használd a „Rendelés lemondása” linket minden oldal láblécében, vagy a Fruugo fiókodban a „Rendelések” alatt. Miután gyakoroltad az elállási jogodat, e-mailben visszaigazolást küldünk neked. Ha a rendelésedet a kiskereskedő már kiszállította, megadjuk a szükséges visszaküldési utasításokat, hogy a visszatérítést mihamarabb feldolgozzuk.

A teljes lemondási szabályzat megtekintése