Multisensor Attitude Estimation

HUF74,490.00
+ HUF2,449.00 Shipping

Multisensor Attitude Estimation
Sold by:
Multisensor Attitude Estimation

HUF74,490.00

In stock
+ HUF2,449.00 Shipping

14-Day Returns Policy

Buyer protection

Payment methods:

  • Brand: Unbranded

Product details

Product details

Multisensor Attitude Estimation

There has been an increasing interest in multi-disciplinary research on multisensor attitude estimation technology driven by its versatility and diverse areas of application such as sensor networks robotics navigation video biomedicine etc. Attitude estimation consists of the determination of rigid bodiesâ orientation in 3D space. This research area is a multilevel multifaceted process handling the automatic association correlation estimation and combination of data and information from several sources. Data fusion for attitude estimation is motivated by several issues and problems such as data imperfection data multi-modality data dimensionality processing framework etc. While many of these problems have been identified and heavily investigated no single data fusion algorithm is capable of addressing all the aforementioned challenges. The variety of methods in the literature focus on a subset of these issues to solve which would be determined based on the application in hand. Historically the problem of attitude estimation has been introduced by Grace Wahba in 1965 within the estimate of satellite attitude and aerospace applications. This book intends to provide the reader with both a generic and comprehensive view of contemporary data fusion methodologies for attitude estimation as well as the most recent researches and novel advances on multisensor attitude estimation task. It explores the design of algorithms and architectures benefits and challenging aspects as well as a broad array of disciplines including: navigation robotics biomedicine motion analysis etc. A number of issues that make data fusion for attitude estimation a challenging task and which will be discussed through the different chapters of the book are related to: 1) The nature of sensors and information sources (accelerometer gyroscope magnetometer GPS inclinometer etc. ); 2) The computational ability at the sensors; 3) The theoretical developments and convergence proofs; 4) The system architecture computational resources fusion level. . Language: English
  • Brand: Unbranded
  • Category: Education
  • Format: Paperback
  • Language: English
  • Publication Date: 2020/09/30
  • Publisher / Label: CRC Press
  • Fruugo ID: 337363073-740990706
  • ISBN: 9780367655815
Promise

Seller guarantee

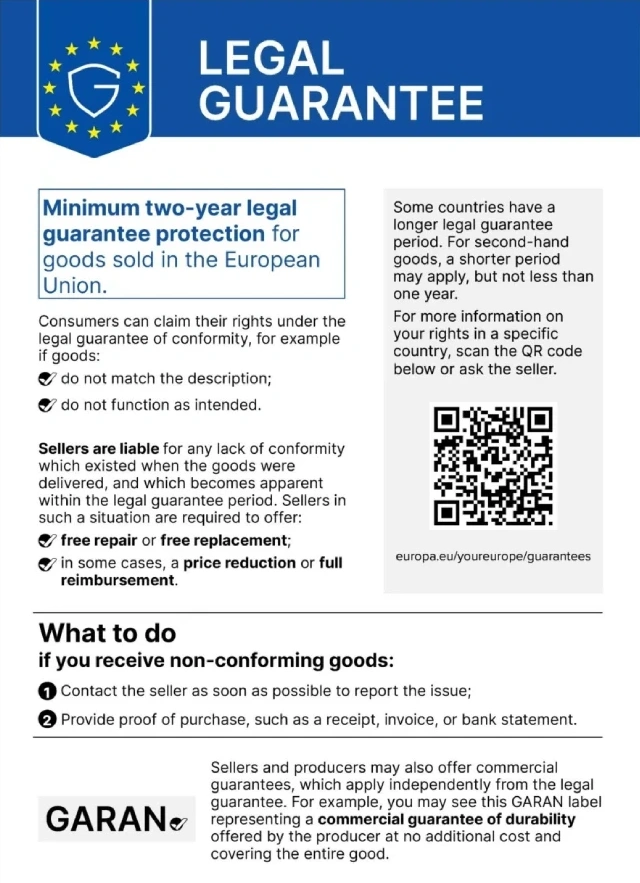
2-year legal guarantee included

Your EU consumer rights include a free minimum 2-year legal guarantee.

Download Legal Guarantee of conformity
Delivery

Delivery

Dispatched within 5 days

  • STANDARD: HUF2,449.00 - Delivery between Tue 10 November 2026–Fri 13 November 2026

Shipping from United Kingdom.

Returns

Returns & Cancellations

Returns

We do our best to ensure that the products that you order are delivered to you in full and according to your specifications. However, should you receive an incomplete order, or items different from the ones you ordered, or there is some other reason why you are not satisfied with the order, you may return the order, or any products included in the order, and receive a full refund for the items.

View full return policy

Cancellations

You have the right to withdraw from your purchase within 14 days from receiving your order without giving a reason. To exercise your right easily, you can use the "Cancel my order" link in the footer of every page or within your Fruugo account under "Orders". Once you exercise your right to withdraw, we will send you an email acknowledgment. If your order has already been shipped by the retailer, we will provide you with the necessary return instructions to ensure your refund is processed promptly.

View full cancellation policy